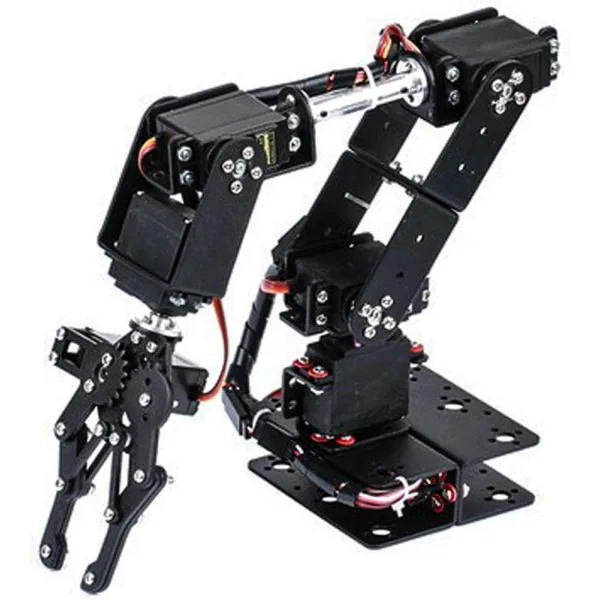
An arm is the first build where position stops being a vague idea and becomes four numbers. Base, shoulder, elbow, gripper — record them at a pickup point, record them at a drop point, and you have taught the machine a job.
Start by driving it live with a joystick, so you can feel what each joint does. Then switch to recorded positions and the arm repeats the move on its own, which is exactly how industrial robots are programmed.
What you'll learn
- Driving multiple servos without browning out the board
- Mapping joystick input to joint angles
- Recording and replaying a sequence of positions
- Why a separate servo power supply is not optional
Choose your components
Build Robotic arm that picks and places: Complete Components Kit
Select the hardware you need, then add your selected components to your RoboSixLab shopping cart. Untick anything you already own.
Tools you'll need
- Hex keys (usually included)
- Small screwdriver
- A bench power supply or a 5V 3A adapter
Tools are not included in the pack or the component list.