Every school robotics competition has a line-following event, and every team discovers the same thing: building it takes an afternoon, making it fast takes judgement.
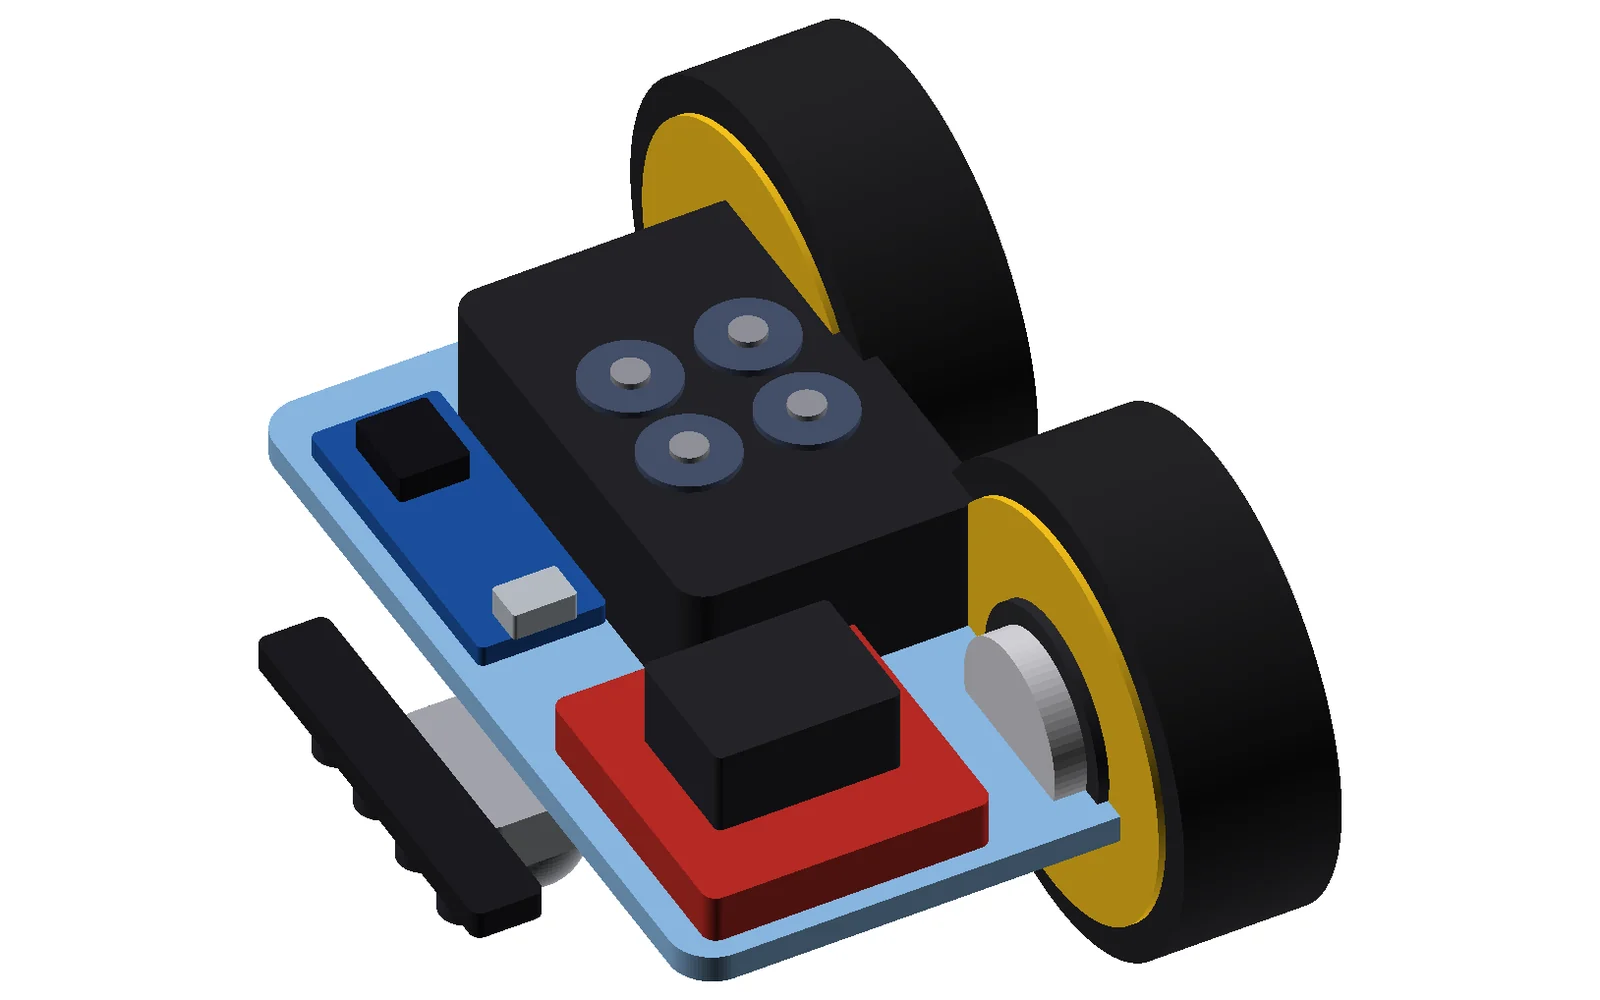
Two infrared sensors look at the floor. Black tape reflects almost nothing, white card reflects a lot, so each sensor returns a clean on/off. If both see white, drive straight. If the left sensor finds the line, turn left. That is the whole program — and then you spend the rest of the session making it smooth instead of twitchy.
What you'll learn
- How infrared reflectance sensing works, and why ambient light matters
- Reading two digital inputs and turning them into four driving states
- Tuning sensor spacing and speed for a stable line
- Debugging with the serial monitor instead of guessing
Choose your components
Build Line follower that stays on track: Complete Components Kit
Select the hardware you need, then add your selected components to your RoboSixLab shopping cart. Untick anything you already own.
Tools you'll need
- Black electrical tape for the track
- Screwdriver
- USB cable
Tools are not included in the pack or the component list.